In modern industrial food manufacturing, processing, and bulk packaging, physical foreign body contamination represents an existential hazard. A solitary fragment of clear conveyor belt plastic in frozen spinach, a shard of transparent glass in bulk diced tomatoes, an insect carcass in roasted almonds, or a splinter of wooden pallet in dry breakfast cereal can trigger catastrophic product recalls, regulatory enforcement actions under FDA FSMA and EU General Food Law, multimillion-dollar civil liabilities, and irreparable brand devastation.
Key Takeaways
- The Blind Spots of Metal Detectors & X-Rays: Traditional food safety inspection relying on metal detectors and density-based X-rays cannot detect low-density foreign materials like soft plastics, rubber gaskets, wood splinters, paper labels, and insects.
- Multi-Spectral & Hyperspectral Fingerprinting: Short-Wave Infrared (SWIR, 900 nm to 1700 nm) spectroscopy and UV fluorescence isolate the chemical signatures of synthetic polymers, aflatoxin mold, and cellulose regardless of product color or surface moisture.
- Free-Fall Trajectory Compensation: High-speed optical sorting requires computing ballistic free-fall velocity vectors at 3 to 5 meters per second to actuate downstream pneumatic air-ejection manifolds with sub-millisecond synchronization.
- Dense Deep Learning Anomaly Detection: Edge-accelerated neural networks (combining 1D spectral CNNs with spatial YOLO segmentation backbones) classify organic food variants and reject non-food contaminants within 3.5 milliseconds.
- Sanitary Design & IP69K Durability: Deploying computer vision directly above bulk food streams mandates 316L stainless steel enclosures, shatterproof sapphire optical windows, and IP69K high-pressure chemical washdown certification.
Summary Overview: Contaminant Detection Modalities Compared
| Contaminant Class | Industrial Metal Detector | Dual-Energy X-Ray System | Hyperspectral & AI Vision System |
|---|---|---|---|
| Ferrous & Stainless Metals | High sensitivity (> 0.8 mm) | Very High sensitivity (> 0.5 mm) | Surface detection only (Visible RGB) |
| Clear Plastic Films & Shards | Completely Blind (Zero conductivity) | Fails (Density identical to water/organic tissue) | 100% Detected (SWIR polymer C-H stretch absorption) |
| Rubber Gaskets & O-Rings | Fails (unless metal-impregnated) | Marginal on dense silicone; fails on EPDM | High sensitivity (Color & spectral separation) |
| Wood Splinters & Cardboard | Completely Blind | Fails (Low physical density) | 100% Detected (Lignin/cellulose SWIR signature) |
| Thin Glass Slivers in Liquid/Ice | Completely Blind | High for dense thick glass; poor for slivers | High (Polarized refractive edge scattering) |
| Biological Defects / Toxins | None | None | Aflatoxin mold, decay, core rot (UV / SWIR) |
For decades, food processing plants relied on a standard downstream inspection duo: an inline metal detector paired with a bulk X-ray machine. While this combination effectively catches broken mixer blades or heavy stones, it leaves a massive blind spot for low-density foreign materials. Consumer complaints in the food sector reveal that over 75% of physical contaminant incidents involve non-metallic, low-density foreign objects: fragments of blue nitrile gloves, shredded polyethylene bag liners, silicone gasket tears from pumps, field insects in leafy greens, and splintered pallet wood.
Because soft plastics, rubber polymers, and organic plant matter share virtually the same X-ray absorption cross-section as water and dietary carbohydrates, X-ray beams pass through them without casting a discriminable shadow. Metal detectors cannot detect non-conductive plastics. To close this critical safety gap, food processors are deploying automated multi-spectral and hyperspectral computer vision inspection cells directly over bulk inspection belts and free-fall chutes. By combining visible RGB color analysis, UV-induced fluorescence, Short-Wave Infrared chemical spectroscopy, and millisecond pneumatic air-ejector sorting manifolds, these systems eliminate foreign materials at full production scale. Engineering leaders can partner with our specialized team to explore customized manufacturing AI solutions tailored for food plant automation.
Evaluating Automated Optical Inspection for Your Line?
Send us 5–10 sample images of your OK/NG parts or share your cycle-time and lighting constraints. Our Computer Vision architects will benchmark detection feasibility within 48 hours—or join a 20-minute technical scoping session.
The Multi-Modal Optical Spectrum: Seeing What Density Misses
Organic food products—such as nuts, frozen vegetables, dried berries, French fries, and grains—exhibit complex natural variability in shape, moisture, and color. A single bruised potato chip or green grape does not look identical to another. Catching a tiny piece of clear plastic wrapped around a French fry requires looking beyond simple visible color space.
1. Short-Wave Infrared (SWIR) Hyperspectral Imaging
Hyperspectral imaging in the SWIR domain (900 nm to 1700 nm) operates on the physical principle of molecular vibrational spectroscopy. Chemical bonds within molecules absorb specific electromagnetic wavelengths:
- C-H (Carbon-Hydrogen) Bond Stretching: Synthetic plastics and polymers (such as Polyethylene, Polypropylene, PVC, and PTFE) exhibit massive, sharp absorption absorption dips at 1210 nm, 1400 nm, and 1730 nm.
- O-H (Oxygen-Hydrogen) Water Absorption: Organic food items containing moisture (e.g., fresh vegetables, fruit flesh, and meat) absorb heavily at 1450 nm and 1940 nm.
- Lipid & Fat Signatures: Edible oils and animal fats display characteristic absorption peaks at 1215 nm and 1725 nm.
When a stream of frozen blueberries flows under a SWIR push-broom line-scan camera, a fragment of clear polyethylene packaging film looks completely identical to ice and frozen fruit in visible RGB cameras. However, at 1210 nm and 1730 nm, the plastic absorbs the infrared photons strongly while the surrounding berries reflect them differently. By calculating the normalized spectral difference ratio, the plastic fragment lights up with stark, unambiguous optical contrast, regardless of transparency.
2. UV-Induced Fluorescence Imaging
Ultraviolet (UV) inspection utilizes narrow-band UV-A illumination (typically 365 nm or 385 nm LEDs) directed onto the food stream, while cameras equipped with long-pass optical barrier filters capture the visible fluorescence emissions (420 nm to 650 nm). This technique solves two notoriously difficult food safety challenges:
- Aflatoxin and Mycotoxin Fungal Contamination: In tree nuts (almonds, pistachios, walnuts) and corn grains, contamination by Aspergillus flavus mold produces carcinogenic aflatoxins. When excited by 365 nm UV light, these fungal metabolites emit a distinct bright yellow-green fluorescence (BGYF), allowing instant optical identification and ejection of toxic kernels.
- Synthetic Optical Brighteners & Packaging Fibers: Modern packaging papers, cardboard, and white polymer films contain synthetic optical brightening agents (OBAs). Under UV-A light, these brighteners fluoresce intense electric blue, distinguishing micro-fibers and paper fragments from pale food substrates like rice, flour, or pasta dough.
3. Multi-Angle Polarized RGB Visible Imaging
For surface-level contaminants like hair, insects, blue nitrile glove fragments, and glass shards, visible light imaging remains essential. However, wet or frozen food items create specular glare on reflective water films. Utilizing cross-polarized multi-angle line lights illuminates the bulk stream while eliminating glare. Glass shards, which possess sharp planar facets, refract polarized light into distinct bright glints along the edges, revealing transparent slivers resting atop wet leafy greens or diced fruits.
"Food safety cannot rely on human inspectors scanning tons of product an hour. When you combine UV fluorescence with SWIR molecular absorption, contaminants that are physically invisible to the human eye glow like beacons against the organic background."
Deep Learning Real-Time Contaminant Classification
Optical data from multi-spectral line-scan cameras generates massive data bandwidths. A line running at 3 meters per second with 0.5 mm spatial resolution produces over 6,000 image lines per second. Processing this continuous stream requires optimized neural networks running on embedded hardware.
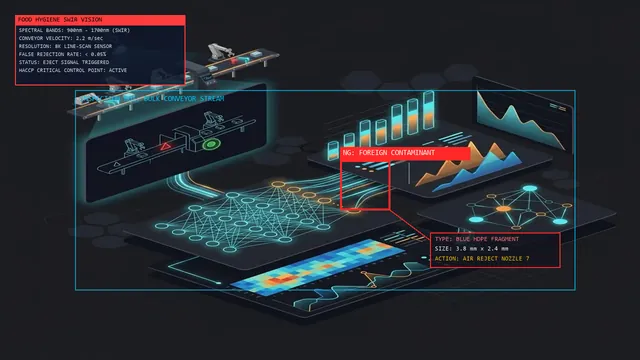
Food Safety Multispectral Inspection Architecture
| Spectral Band | Target Contaminant Class | Optical Mechanism |
|---|---|---|
| SWIR (1,000 - 1,700 nm) | Plastics, rubber gasket shreds, clear glass shards | Severe moisture absorption contrast isolates non-organic fragments. |
| UV-Fluorescence (365 nm) | Aflatoxins, machine grease, pesticide residues | Excitation causes chemical residue to fluoresce bright visible green/yellow. |
| High-Res RGB Line-Scan | Stones, dead insects, discoloration, cardboard | Sub-millimeter color and texture anomaly segmentation. |
| Pneumatic Air Ejector Bar | High-speed valve manifold (64 independent nozzles) | Targets contaminant with 2 ms high-pressure air burst, minimizing product loss. |
1. 1D Spectral Convolutional Networks
Rather than passing raw 256-band hyperspectral cubes through computationally heavy 3D convolutions—which would introduce unacceptable latency on the sorting line—our architecture deploys an optimized two-stage pipeline. A vectorized 1D convolutional neural network (1D-CNN) processes the spectral reflectance vector of each pixel. This model is trained on a comprehensive chemical spectral library encompassing:
- Polyethylene (LDPE/HDPE) and Polypropylene (PP) packaging films.
- EPDM, Nitrile, Neoprene, and Viton industrial rubber compounds.
- Insect chitin and biological carcass tissues.
- Natural wood cellulose and cardboard fibers.
The 1D-CNN outputs a dense classification score for every spatial pixel in less than 1.0 millisecond. Pixels flagged as synthetic polymers or inorganic foreign bodies are clustered into spatial candidate blobs.
2. Spatial Feature Verification and Organic Defect Grading
Simultaneously, the high-resolution RGB and UV images are evaluated by a lightweight convolutional segmentation network. This network evaluates morphological geometry, surface texture, and color variations. In addition to flagging foreign contaminants, the system performs simultaneous quality grading:
- Physical Blemishes: Scabs, insect bites, mechanical bruising on fruits and potato tubers.
- Dimensional Sizing: Verifying length, aspect ratio, and caliber across sliced carrots or nut kernels.
- Bake Color Uniformity: Measuring Maillard reaction color distribution on cookies and crackers.
High-Speed Pneumatic Air Ejection and Ballistic Calibration
Detecting a foreign body is only half the battle; the machine must physically remove the contaminant from a dense, free-falling curtain of product moving at 3 to 5 meters per second without ejecting good product.
The Pneumatic Ejection Valve Array
Downstream of the optical inspection line, products leave the conveyor belt and enter a free-fall ballistic trajectory. Positioned immediately beneath the trajectory chute is a high-speed pneumatic manifold containing up to 128 or 256 ultra-fast solenoid valves (such as MAC Valves 34 series or Festo high-speed valves) spaced at 3 mm to 6 mm center-to-center pitch. These valves operate with an electrical actuation response time under 1.5 milliseconds, discharging a focused blast of clean, dry compressed air at 6 to 8 bar (87 to 116 psi).
Ballistic Time-of-Flight Synchronization
When the camera detects a piece of broken rubber at coordinate (X0, Y0) on the conveyor belt, the vision software calculates the exact millisecond when the foreign object will intersect the air-knife blast plane:
tblast = tdetection + (dbelt_to_lip / vbelt) + √(2 × dfall / g) + Δtvalve_delay
The software precisely activates only the 2 or 3 solenoid nozzles directly aligned with the foreign body's calculated transverse X-coordinate for an air blast duration of exactly 2.5 to 5.0 milliseconds. The targeted pulse deflects the contaminant out of the free-fall trajectory arc into a rejection waste bin, while 99.8% of the surrounding qualified product lands unimpeded in the primary acceptance funnel.
Sanitary Engineering: IP69K Washdown Compliance
Food processing environments are subject to severe cleaning protocols involving daily chemical sanitization with sodium hydroxide, nitric acid, and chlorine foams, followed by 100-bar high-pressure hot water (80°C) washdowns. Commercial automation hardware quickly disintegrates under these conditions.
Our turnkey vision stations are engineered for rigorous food safety compliance:
- 316L Stainless Steel Housing: Enclosures feature electropolished surfaces with a surface roughness of Ra ≤ 0.8 μm, sloping roofs, and zero flat horizontal surfaces to prevent bacterial biofilm pooling, adhering to European Hygienic Engineering & Design Group (EHEDG) guidelines.
- Shatterproof Sapphire and Polycarbonate Optics: Glass lenses are strictly prohibited in open food zones due to shatter contamination risks. Inspection viewports utilize scratch-resistant optical sapphire crystals or FDA-compliant hard-coated polycarbonate windows.
- Vibration and Thermal Compensation: Heavy vibratory conveyors and oscillating sorting shakers transmit mechanical shock. Our camera assemblies incorporate tuned vibration dampeners and active Peltier thermoelectric coolers to prevent sensor thermal drift and focus degradation during continuous washdown cycles.
To learn more about how our custom vision hardware and embedded models integrate into harsh processing lines, visit our computer vision services overview. You can also explore our ruggedized embedded computing deployments at our edge AI development company page, or reach out to our food automation specialists to arrange an optical sample evaluation for your product stream.
Frequently Asked Questions
Why can't industrial X-ray systems detect clear plastic or soft rubber in food?
X-ray inspection relies on physical density and atomic mass differences. Soft plastics (like polyethylene and polypropylene packaging films) and standard rubber gaskets have densities almost identical to water, vegetable tissue, and carbohydrates. As a result, the X-ray beam attenuates equally across the food and the plastic, producing zero discernable contrast shadow.
How does Short-Wave Infrared (SWIR) identify foreign materials regardless of color?
SWIR hyperspectral imaging measures chemical molecular bonds rather than visible color. Synthetic polymers contain carbon-hydrogen bonds that absorb distinct wavelengths in the 1200 nm to 1730 nm band. Natural organic foods contain water and moisture that absorb strongly at 1450 nm. By measuring these spectral absorption fingerprints, the vision system clearly isolates plastics, rubber, and wood regardless of whether the material is transparent, white, or dark.
What is the sorting capacity of a high-speed pneumatic optical sorter?
Modern automated optical sorters inspect free-falling product curtains traveling at 3 to 5 meters per second across chute widths of 600 mm to 1200 mm. Depending on the bulk density of the product (such as nuts, seeds, cut vegetables, or grain), these systems routinely process between 2 and 15 metric tons of material per hour with sub-millisecond ejection precision.
Can the vision system operate in harsh IP69K chemical washdown environments?
Yes. The inspection stations are built within electropolished 316L stainless steel enclosures meeting IP69K ingress protection ratings. They feature shatterproof sapphire or FDA-grade polycarbonate viewports, sealed silicone gaskets, and sanitary sloped geometries that withstand 100-bar high-temperature chemical sanitation washdowns without optical misalignment or water penetration.
How does the system prevent false rejects and avoid wasting good food?
The system combines deep learning segmentation with high-speed solenoid nozzle arrays spaced just a few millimeters apart. Instead of dumping large portions of the product stream, the software calculates the exact ballistic trajectory of the foreign particle and fires only the two or three nozzles directly aligned with the contaminant for 3 milliseconds, minimizing good product loss to under 0.2%.